My Projects
Work
Dominion Dynamics
Human Computer Lab
Sellstatic
UTIAS
Research
Integrating UAV Controls into Navigation
Vision models deployed on a drone's onboard compute, integrated with ROS for navigation control.
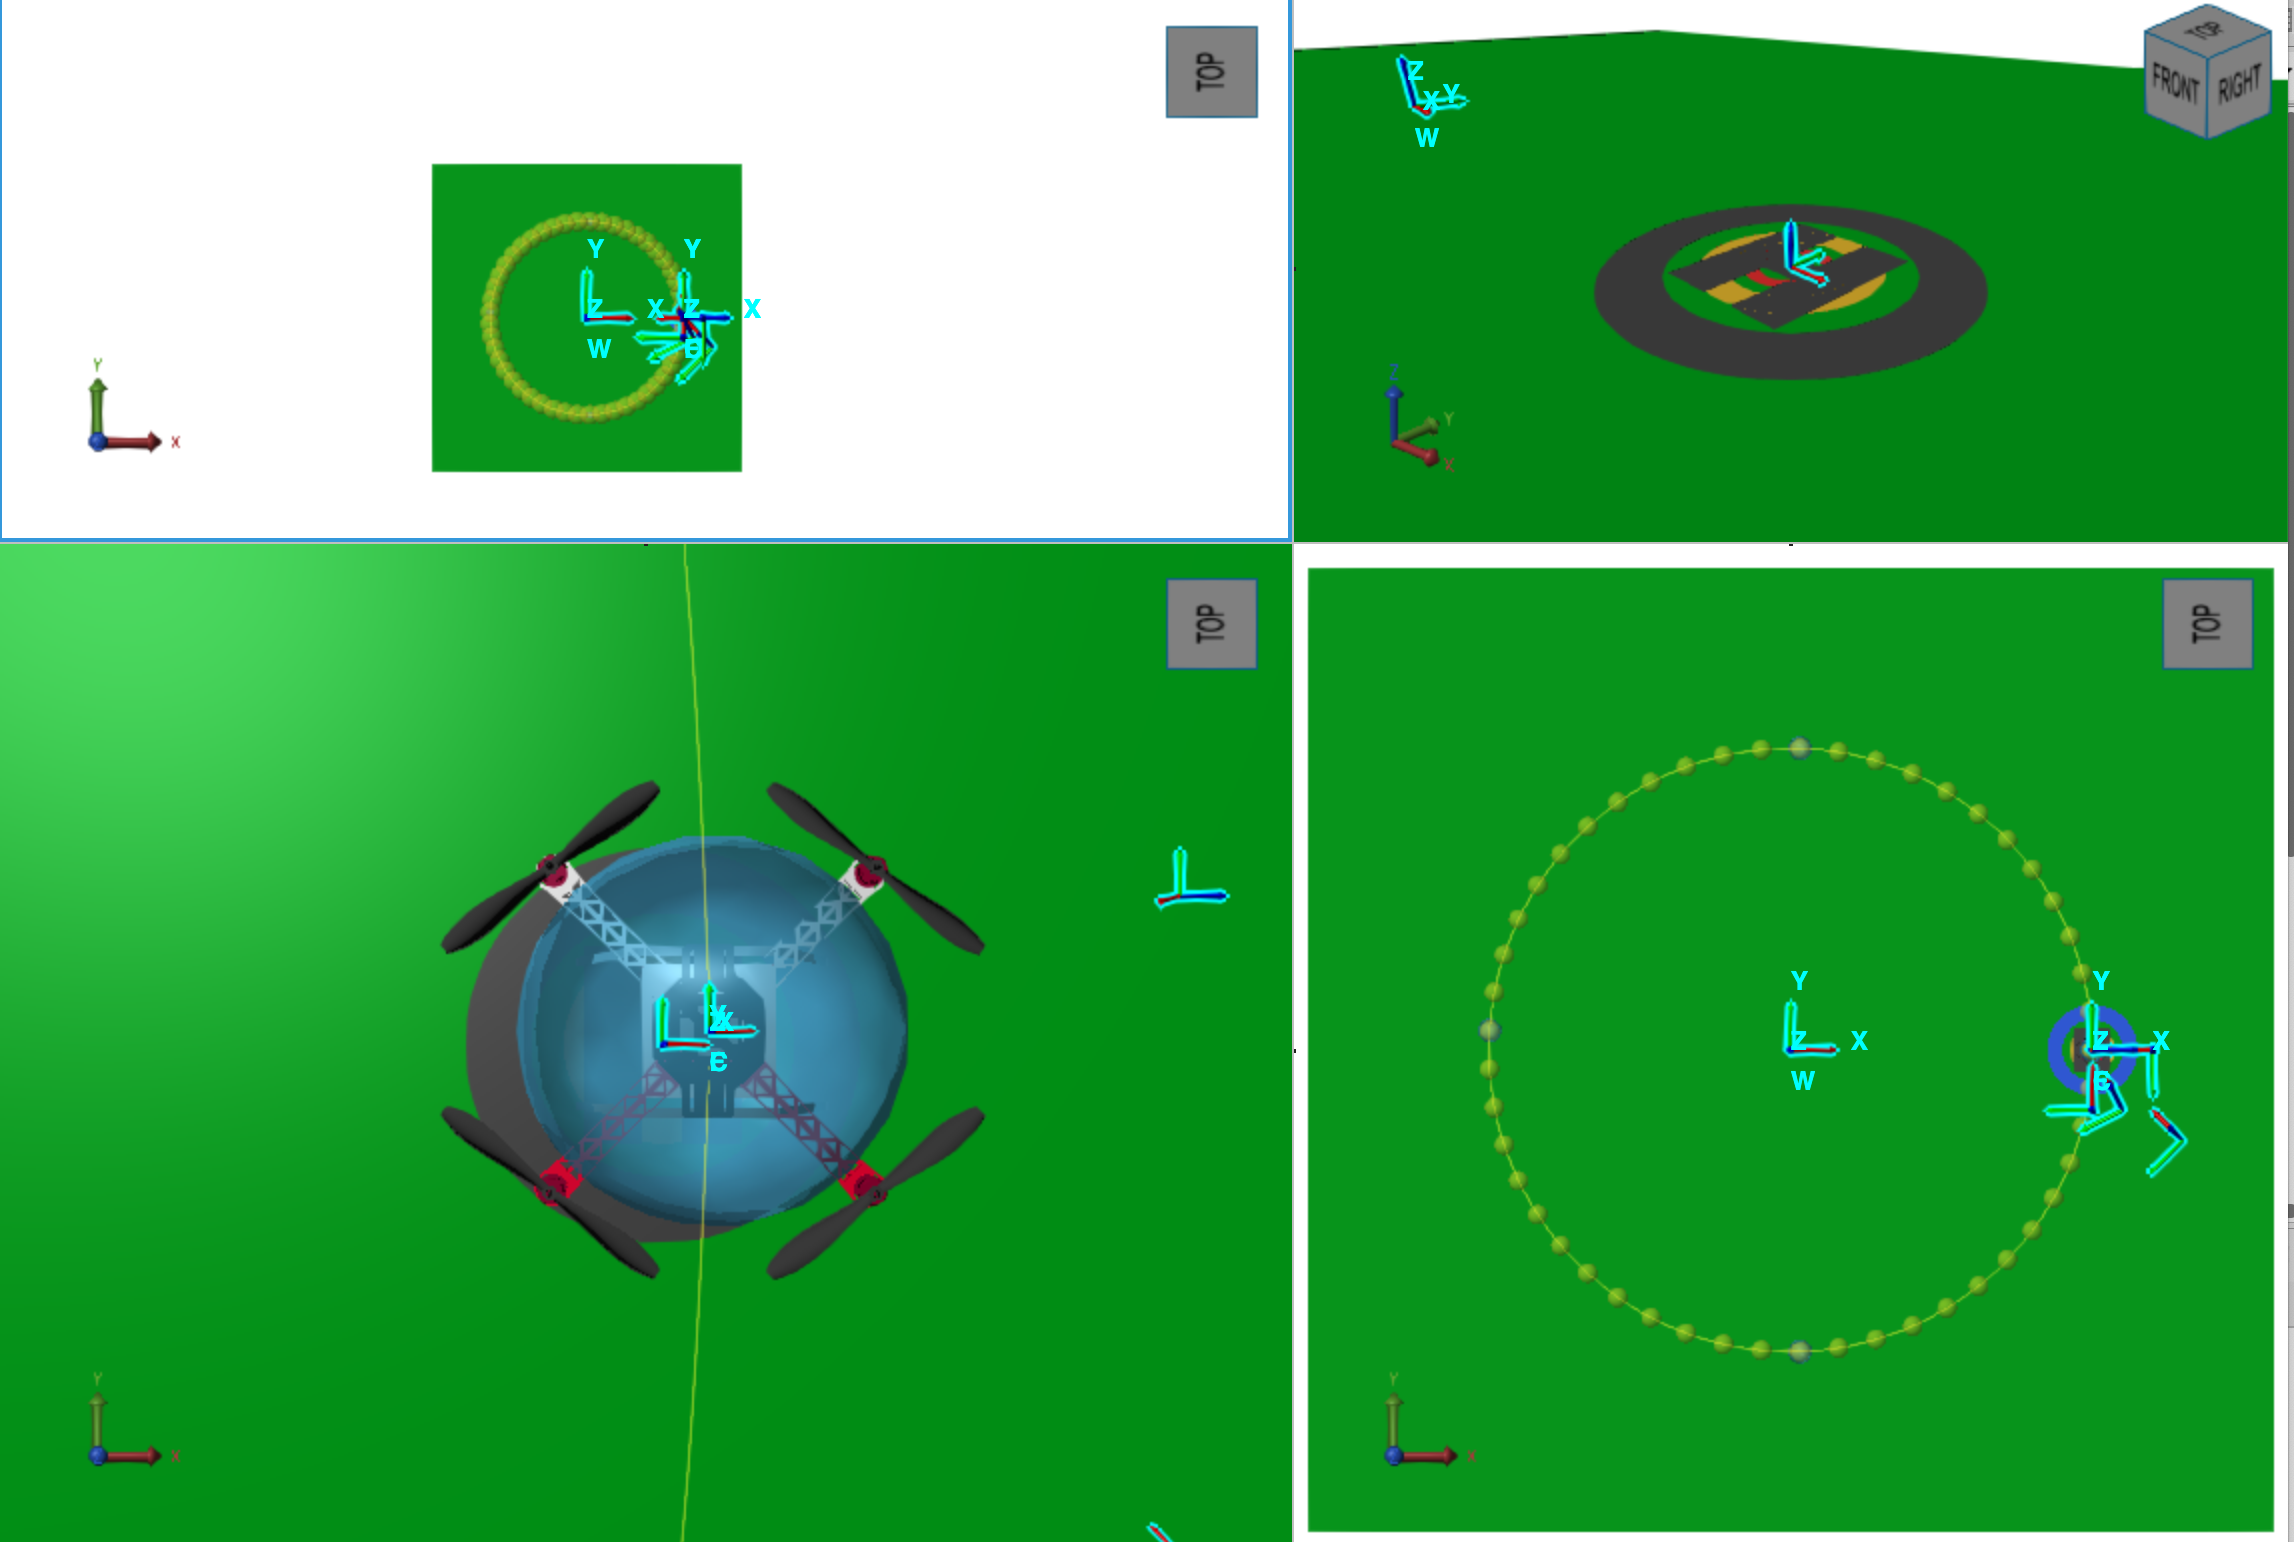
Optimizing UAV Autonomous Navigation
Quadrotor co-simulation with cascaded attitude control design and tuning.
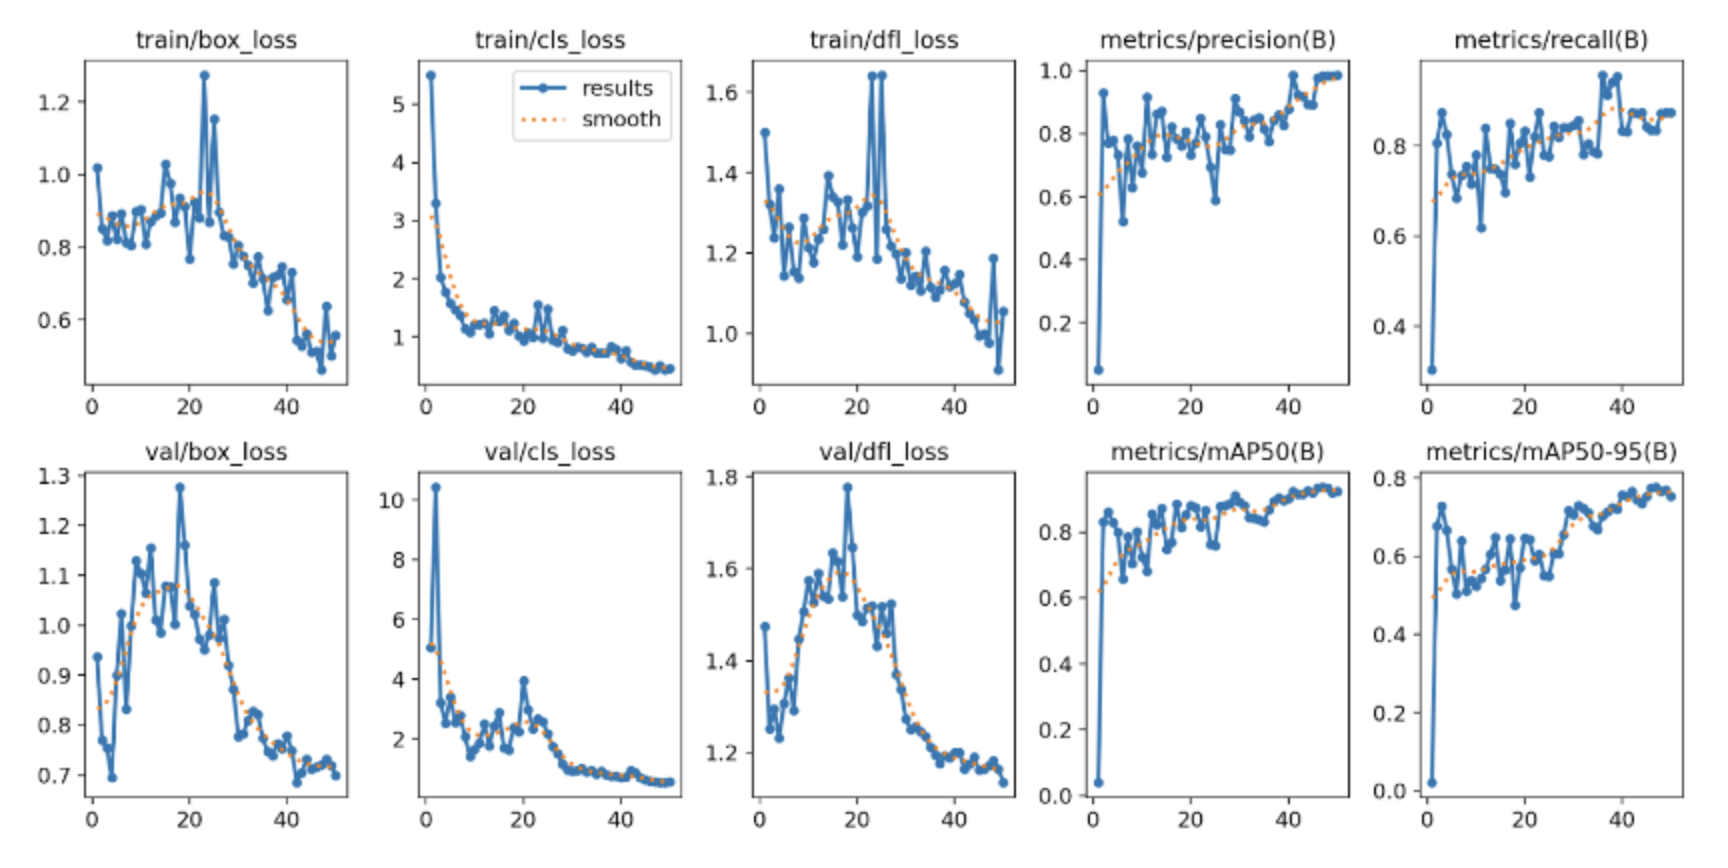
UAV Navigation Model Training
A YOLOv8 gate detector trained for autonomous drone racing navigation.
Projects
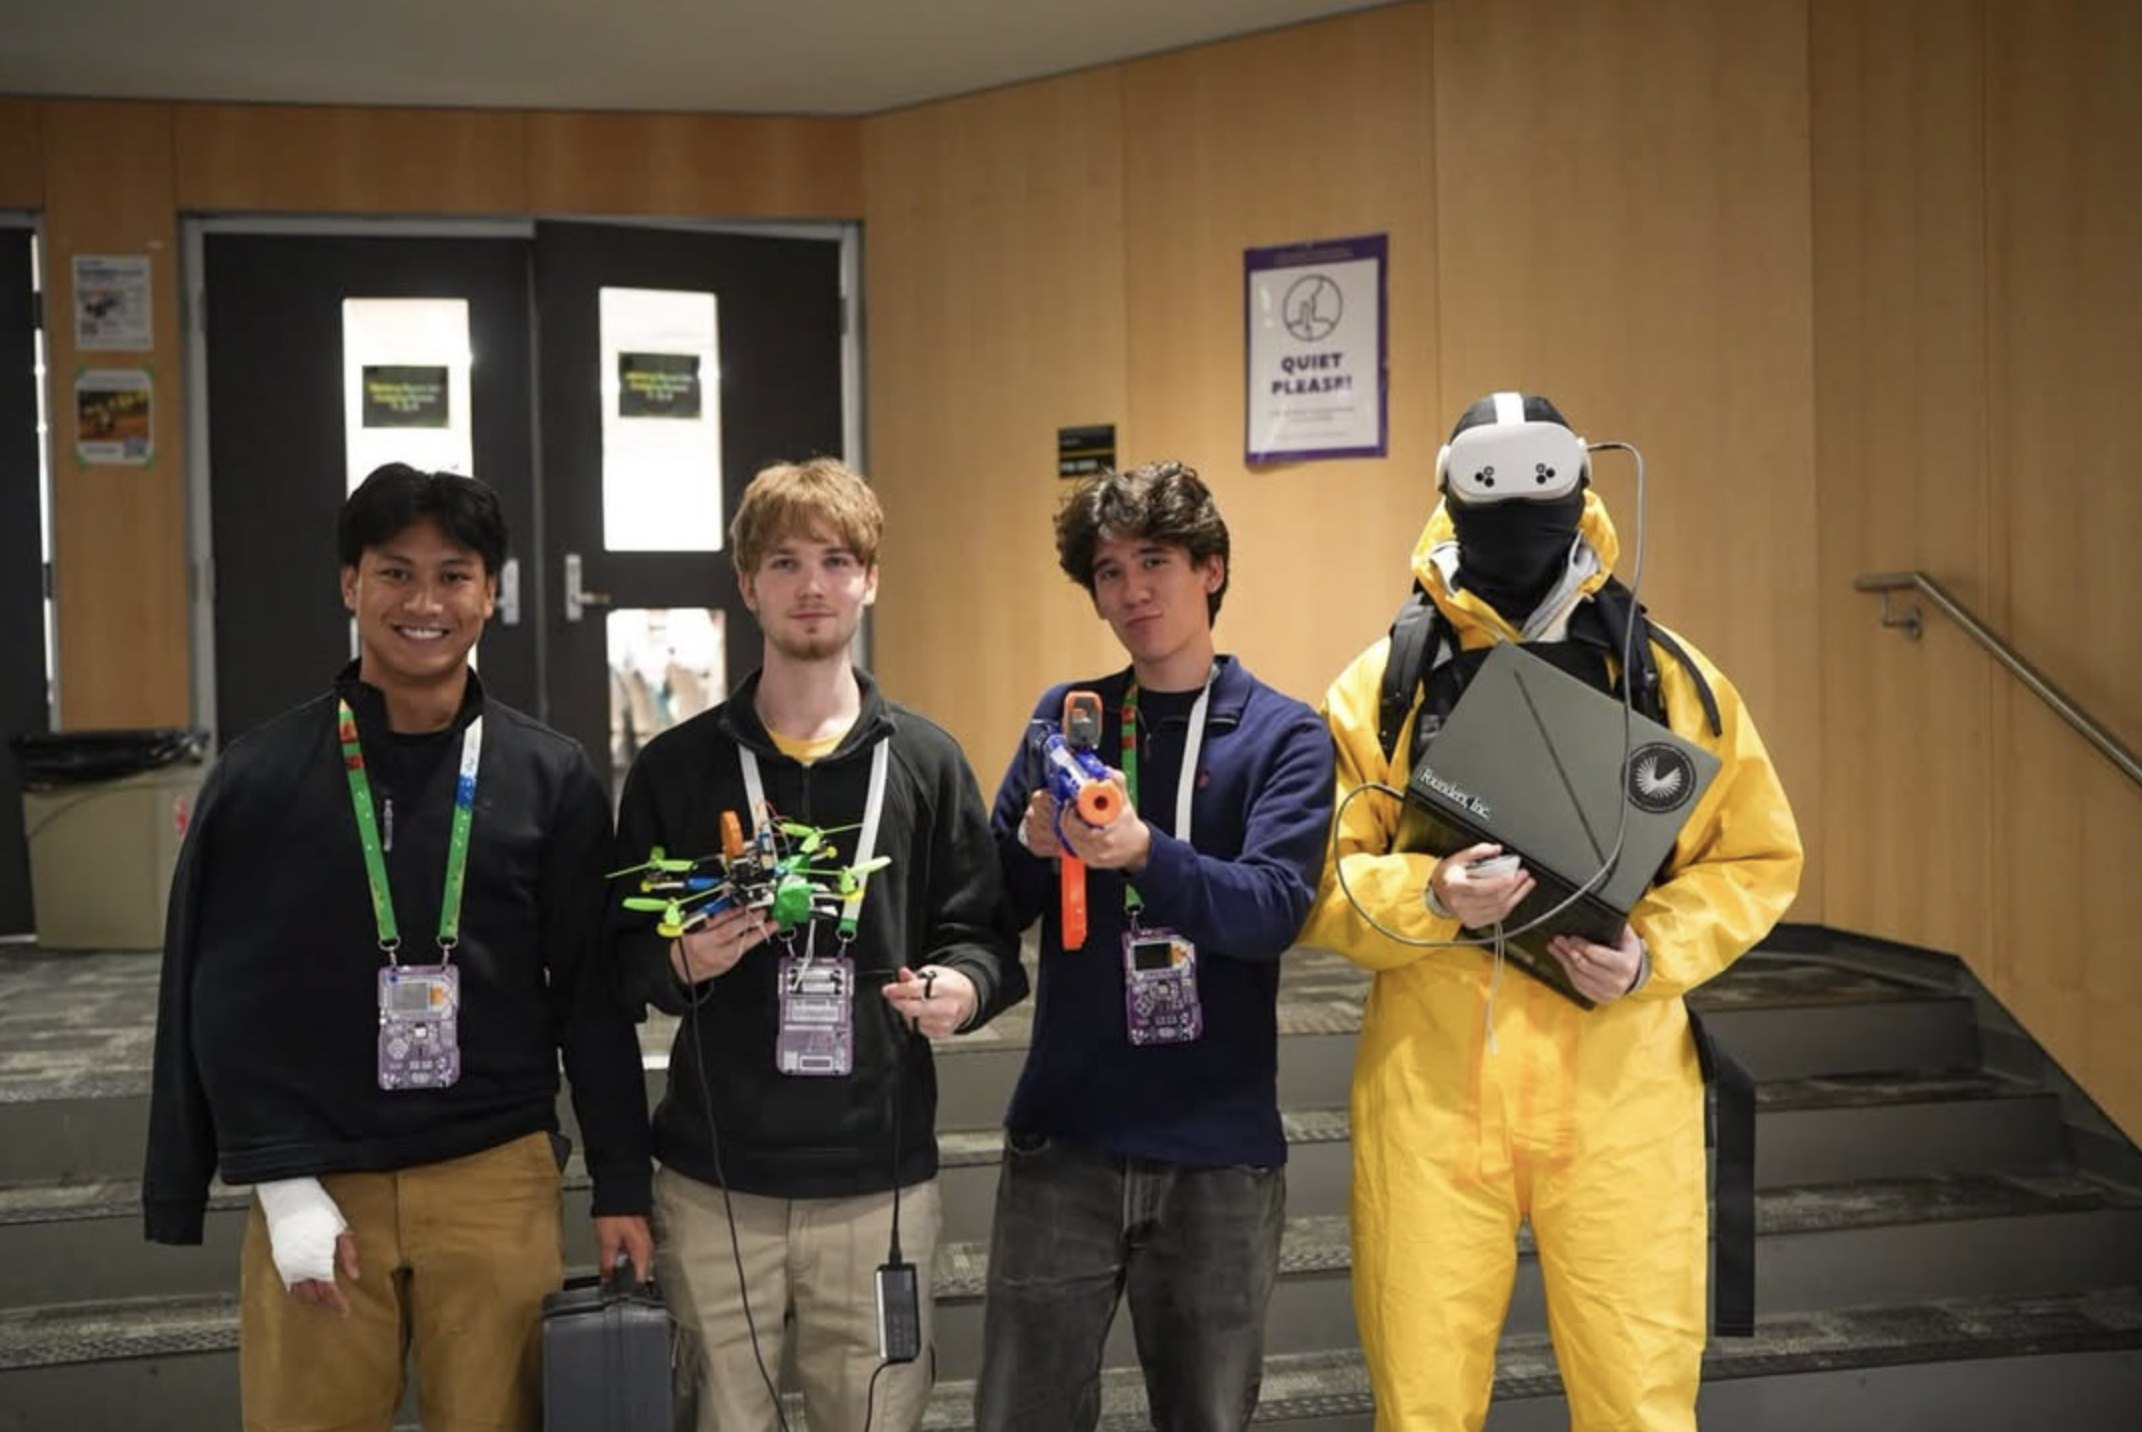
Sharingan
A scout drone built to see through walls from its own vantage point — fusing an onboard camera, mmWave radar, and WiFi CSI sensing into a single live picture of what's on the other side.
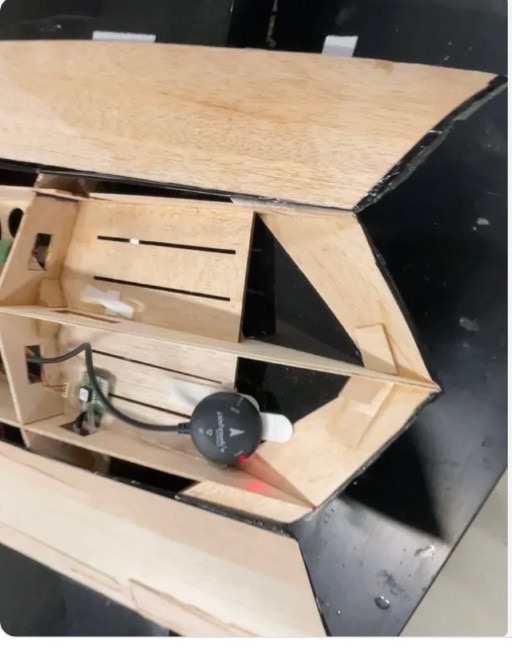
Fixed-Wing UAV Airframe Design
Laser-cut wing iterations and a heat-shrink prototype skin for a fixed-wing airframe.
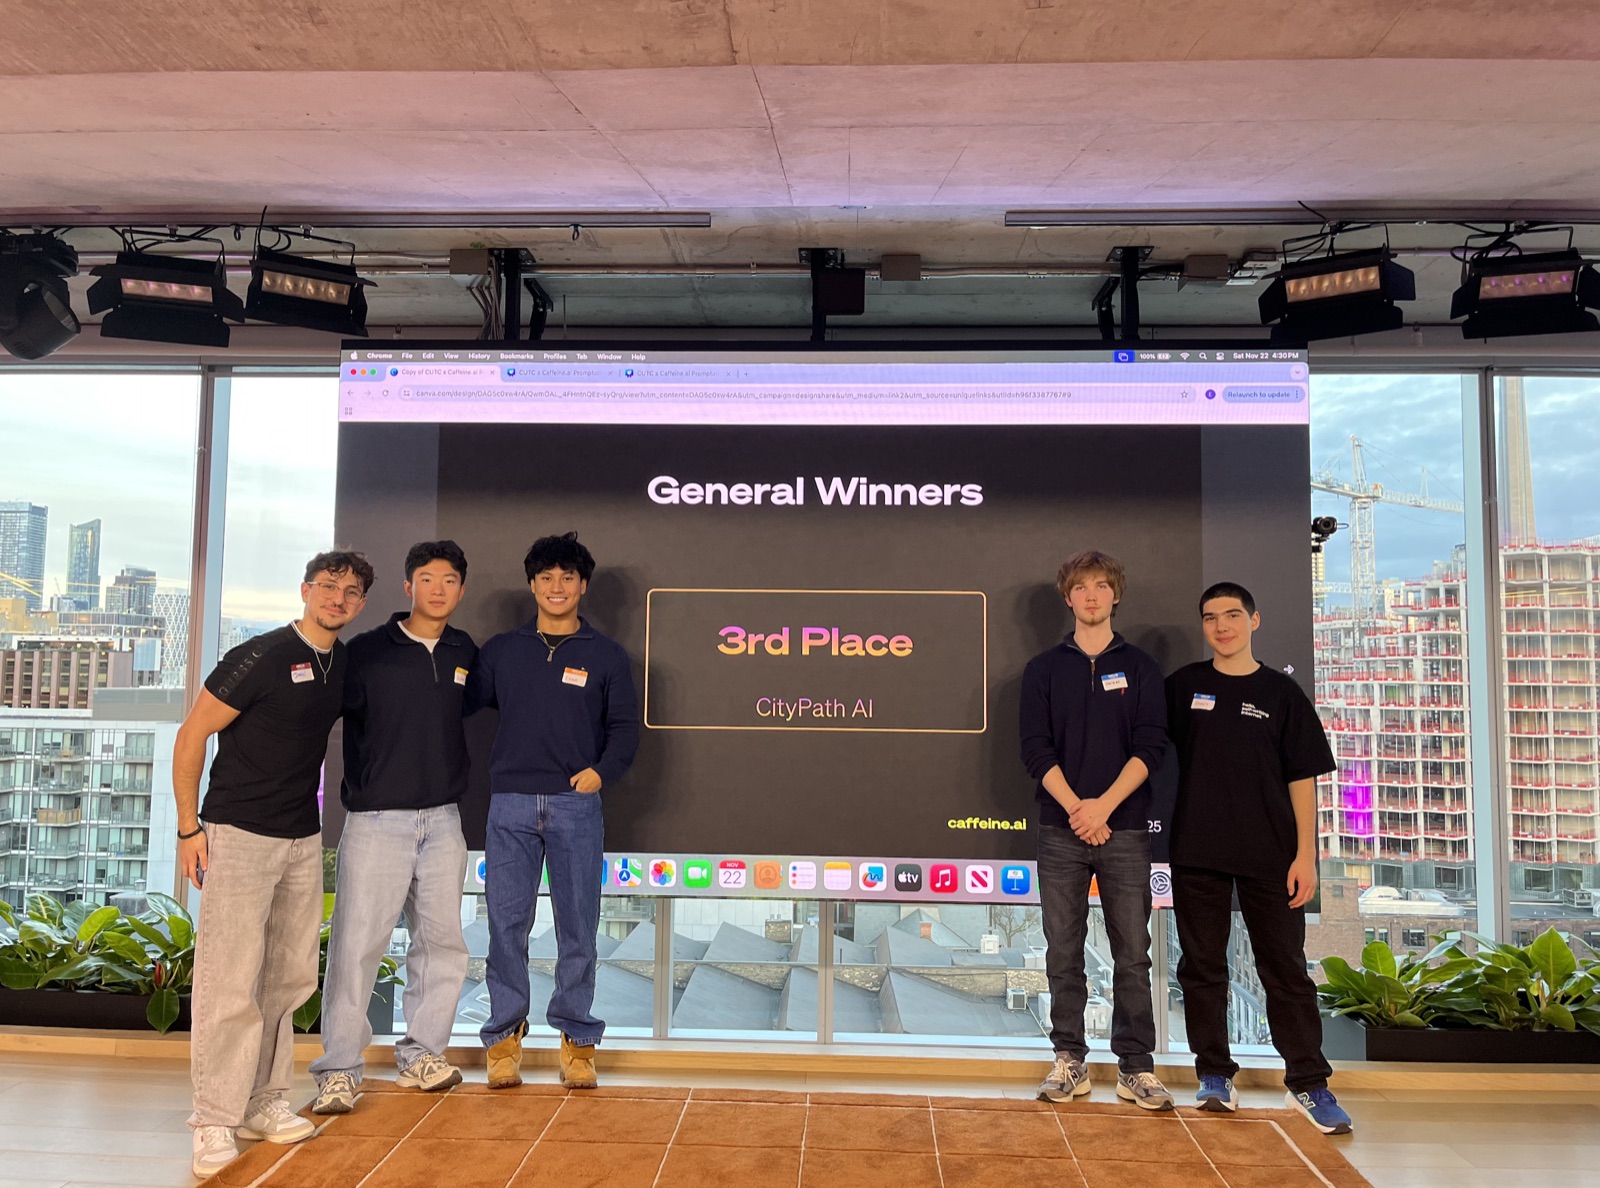
CityPath AI
Analyzes street safety patterns from city data. 3rd place.
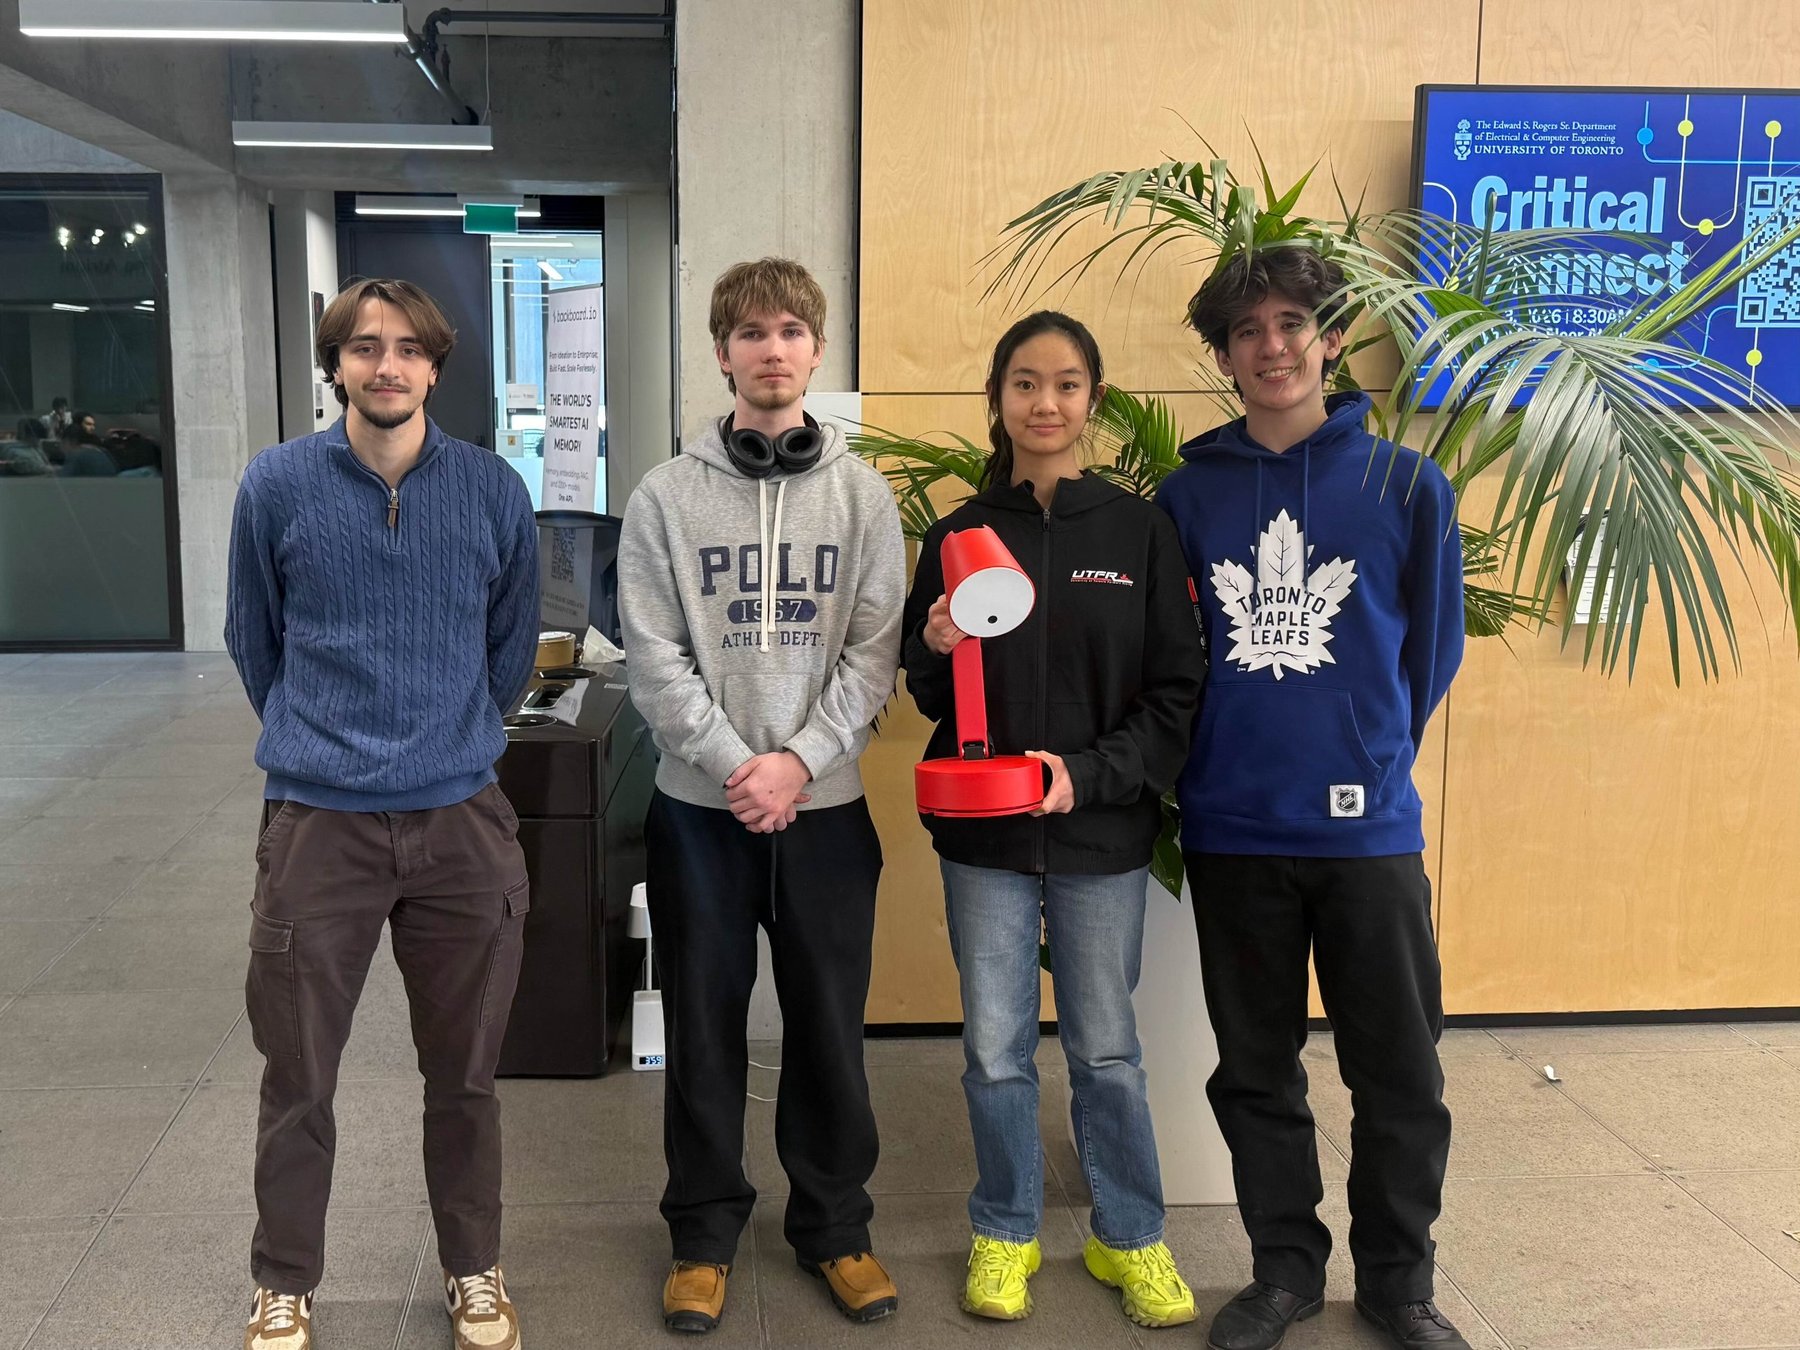
RedLamp
A study lamp that detects student stress. 2nd place.
Jane Street Estimation Competition
Fermi estimation competition. Placed 1st.
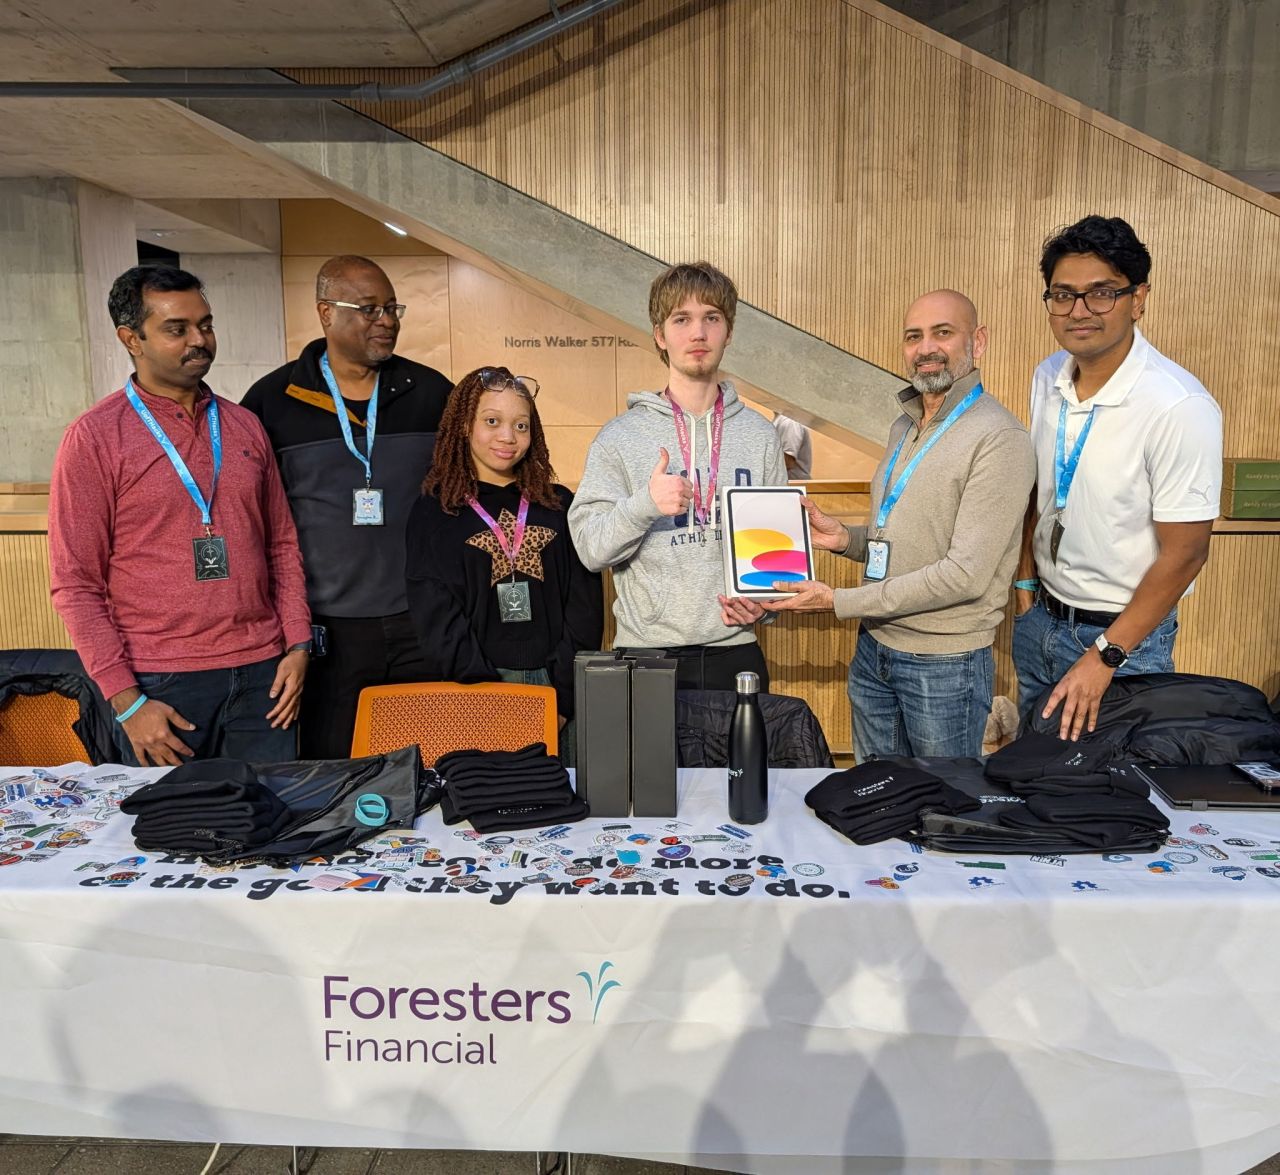
Foresters Financial Development Challenge
Fintech case competition. Placed 1st.
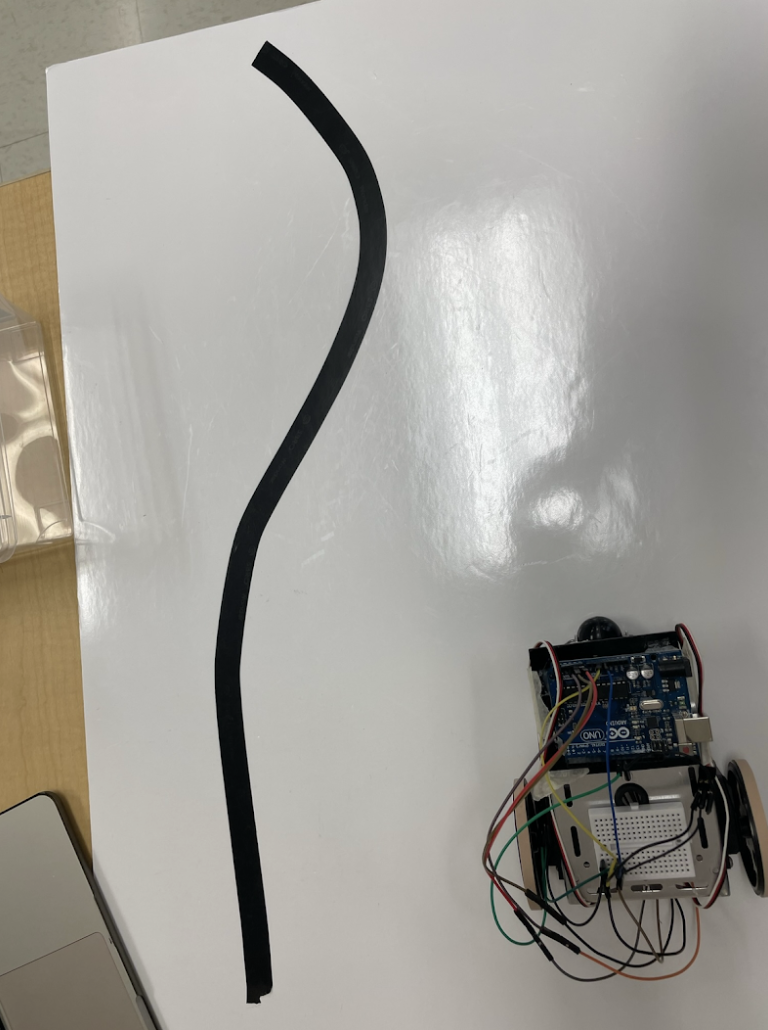
Car Line Follower
Infrared sensors and Arduino logic for autonomous line-following.
Car with Obstacle Detection
An Arduino-controlled car that detects and avoids obstacles in real time.
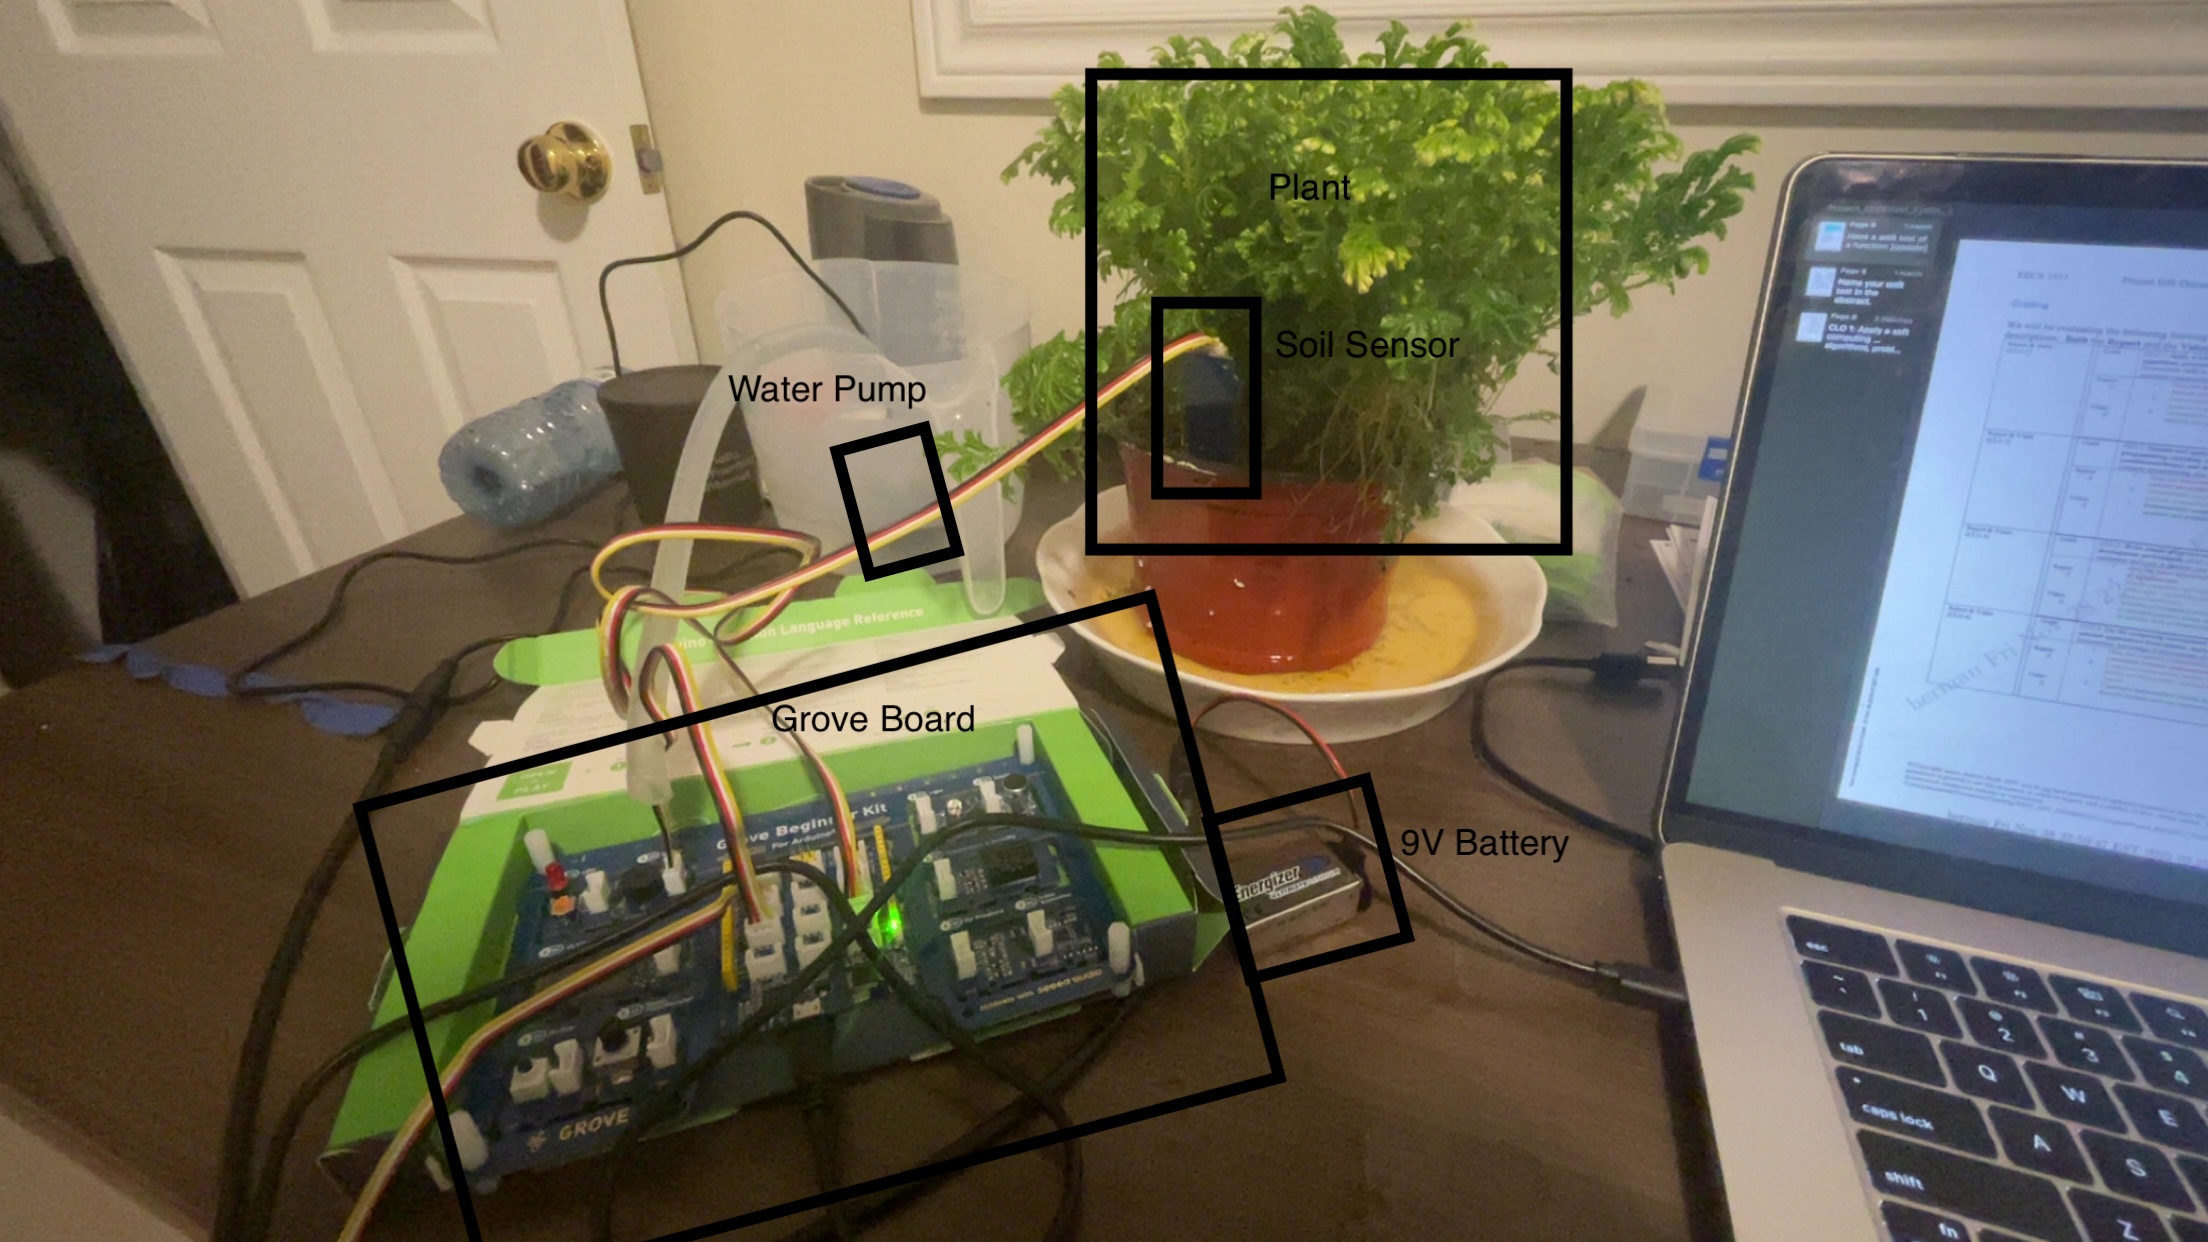
Autonomous Water Pump
Waters plants automatically based on live soil moisture readings.
Digital Timer
An Arduino-driven timer built around a 555 timer IC.
Digital Clock
An Arduino-based clock driving a 7-segment display.
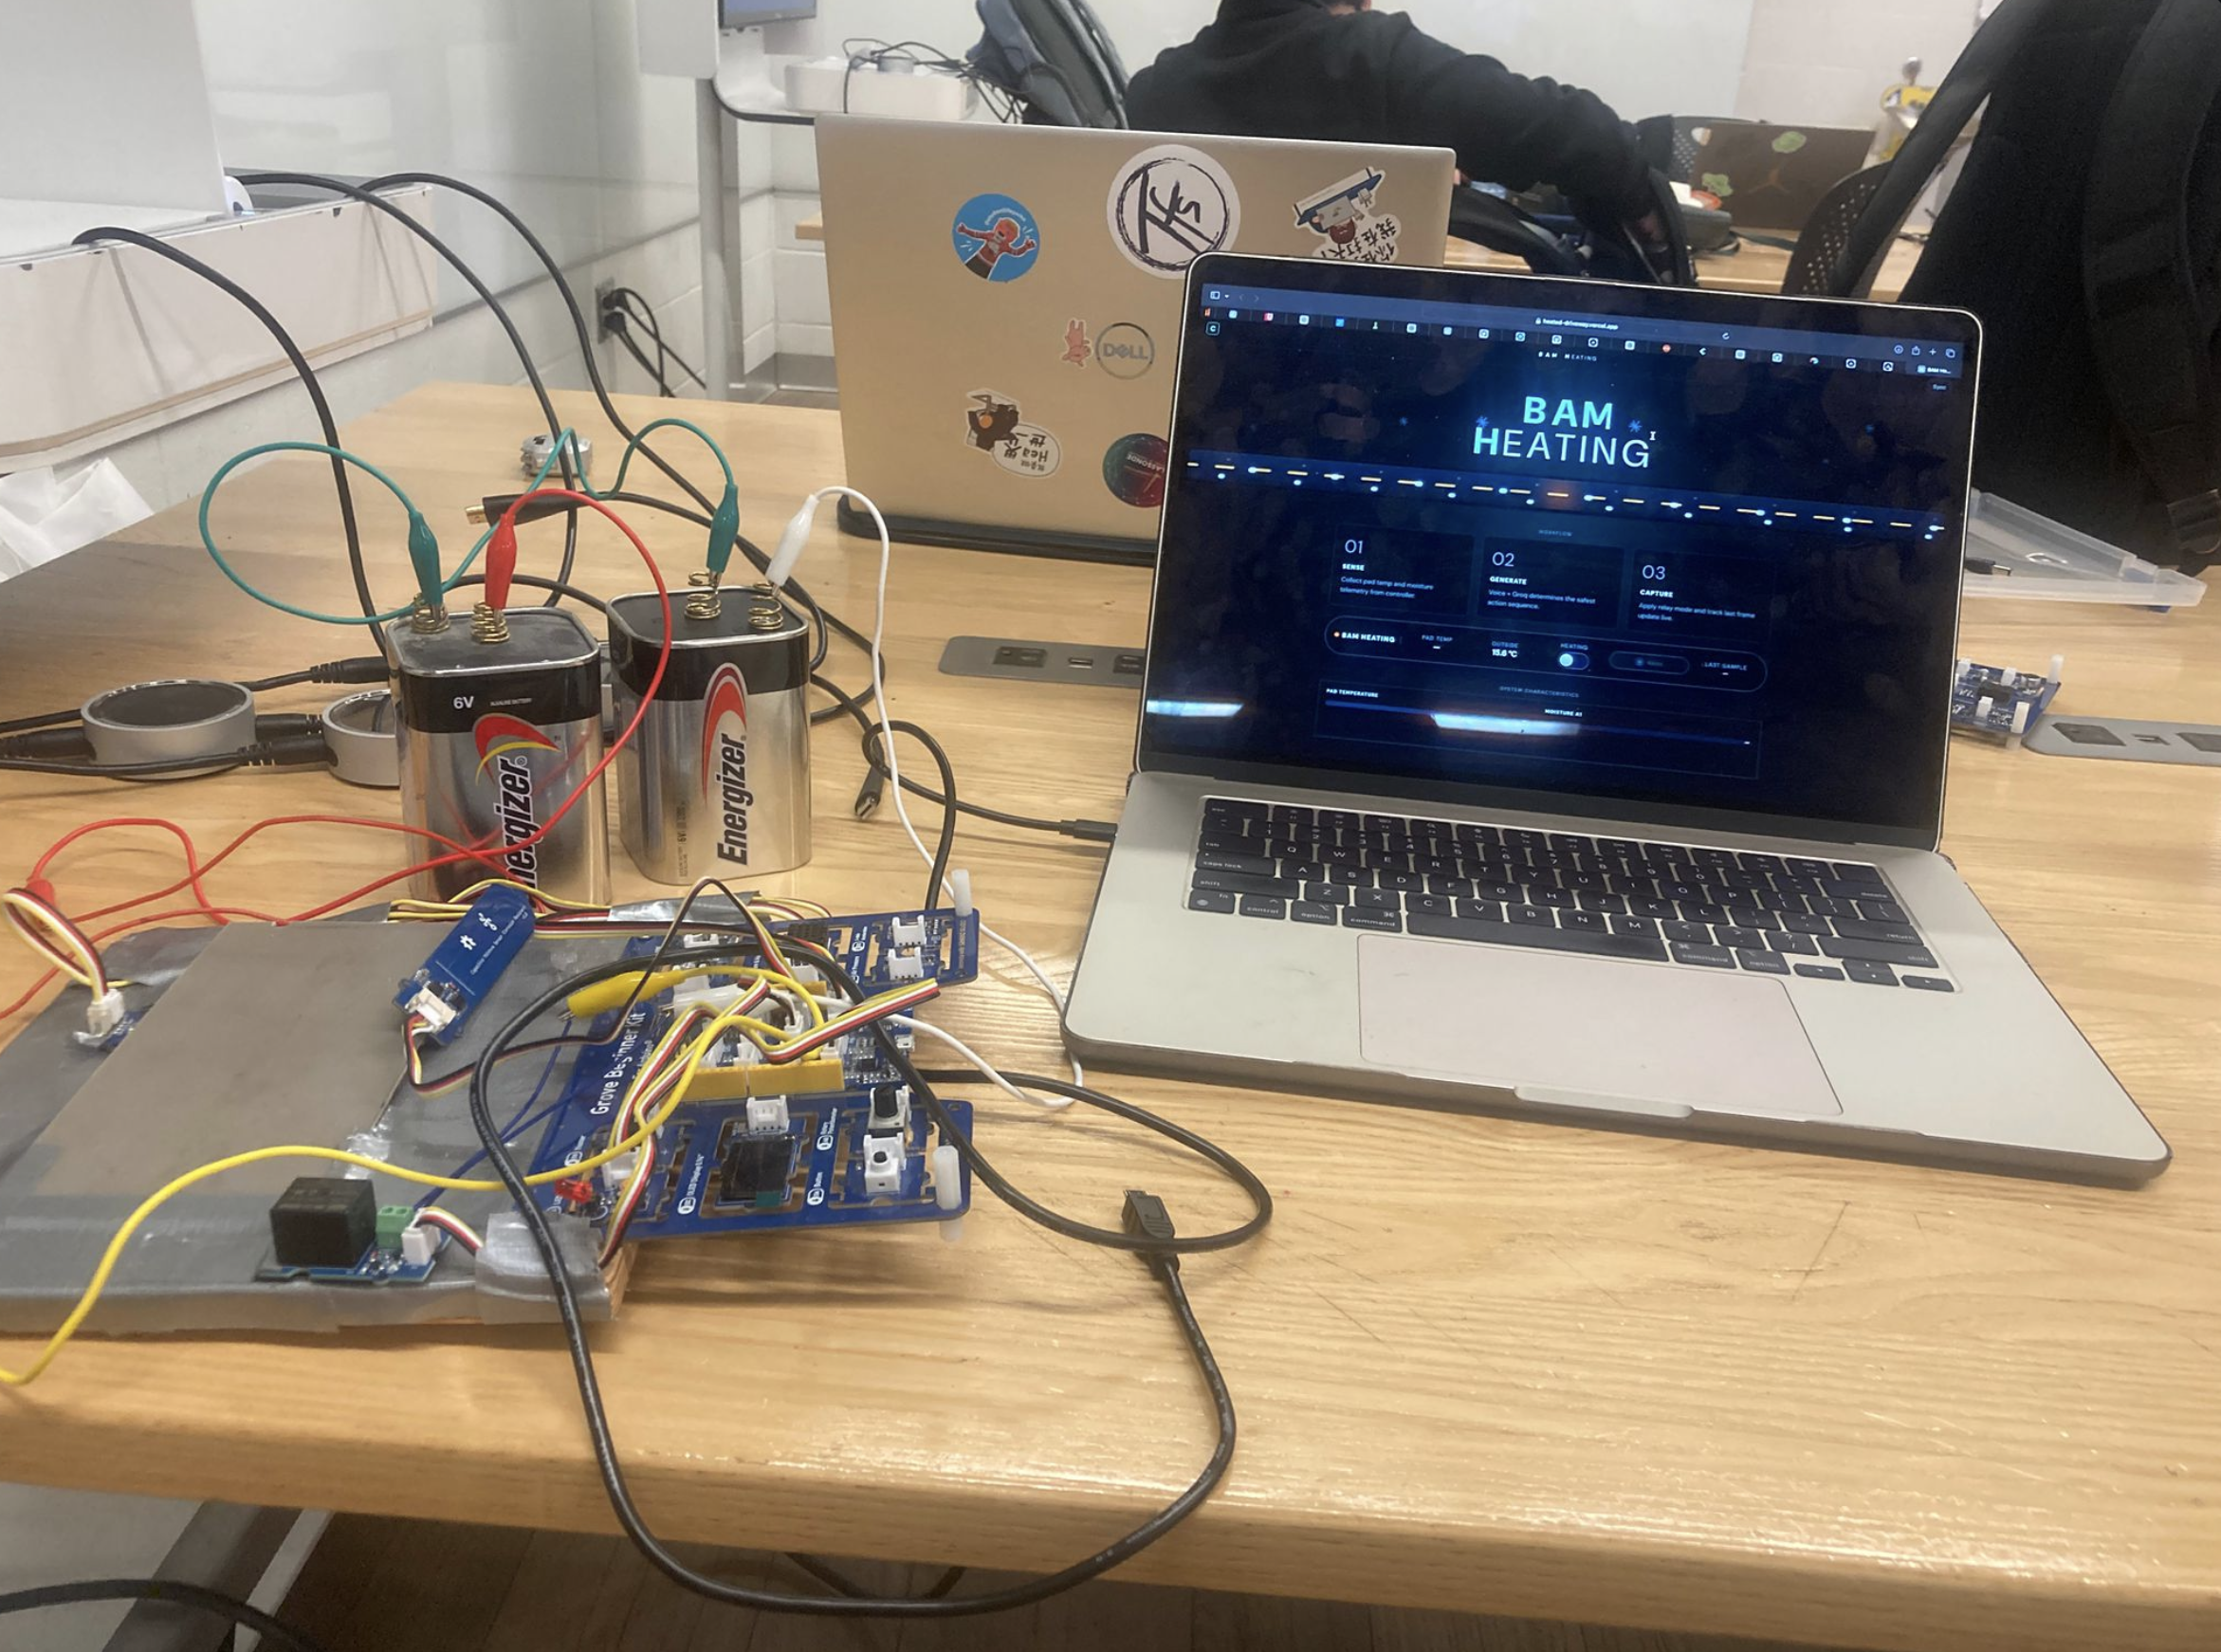
Heated Driveway
Snow detection and heating controller with a live monitoring dashboard.
GrowthSync
Visualizes subdivision impact for city planners.
Finding N.E.M.O
A shipping-container recovery simulation.
Giveway
Meal requests paired with optimized driver routing.
Meal2Go
Health-tailored meal recommendations.
KinKitchen
3D step-by-step recipe walkthroughs.